Bubble/360 Panoramic view support with E57 files
Written By Nira.app
Last updated About 10 hours ago
E57 is one supported panorama workflow. You can also upload panoramic JPG images with a CSV pose file alongside mesh or 3D Gaussian Splat data. The E57 checks below apply specifically to panoramas embedded in E57 files.
Panorama controls
Panoramic 360 images have their own section in Settings, separate from Point Cloud settings. You can hide the point cloud while keeping panoramas visible alongside a mesh or 3D Gaussian Splat.
Use Show Names to show or hide panorama setup names on hover. Horizontal Filtering and Vertical Filtering limit the available setups by their distance from the current viewpoint, making nearby panoramas easier to find.
Checking embedded E57 panoramas
Nira supports bubble/360 Panoramic with E57 files. For this feature to work, your e57 files must contain embedded image data. Currently, Nira will not reconstruct a panoramic image from structured scan data. The following applications support embedding image data into e57 files:
- RIEGL RiSCAN PRO
- Leica Cyclone Register 360
- NavVis
- Faro SCENE
The following do not support embedding image data into e57 files:
- Trimble RealWorks
- Autodesk ReCap
To check if an E57 file contains embedded image data, you can use E57 Inspector. Simply open your E57 file with the tool, if it includes image data, it will be displayed like this:
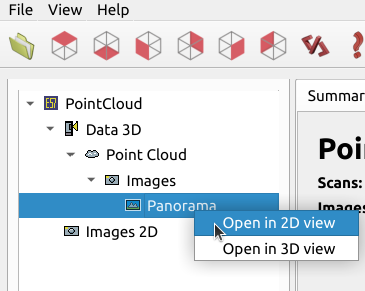
Please note that there is an “Images” section that can be expanded. Beneath the images section, you should be able to right-click on the subitems to display the “Open in 2D view” and “Open in 3D view” options for each image.
If it does not contain image data, it will look like this:
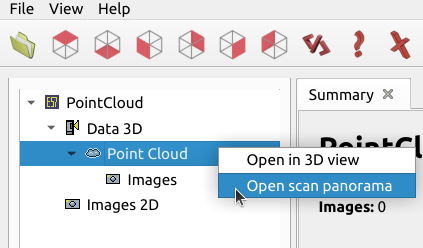
Notice that the “Images” section is NOT expandable. This means that the file does not contain image data, and the bubble / panoramic views will not be supported in Nira. The “Open scan panorama” option can be used to open a panoramic viewer, but this option is not showing an actual embedded image, instead, it is constructing a panoramic from the scan data.